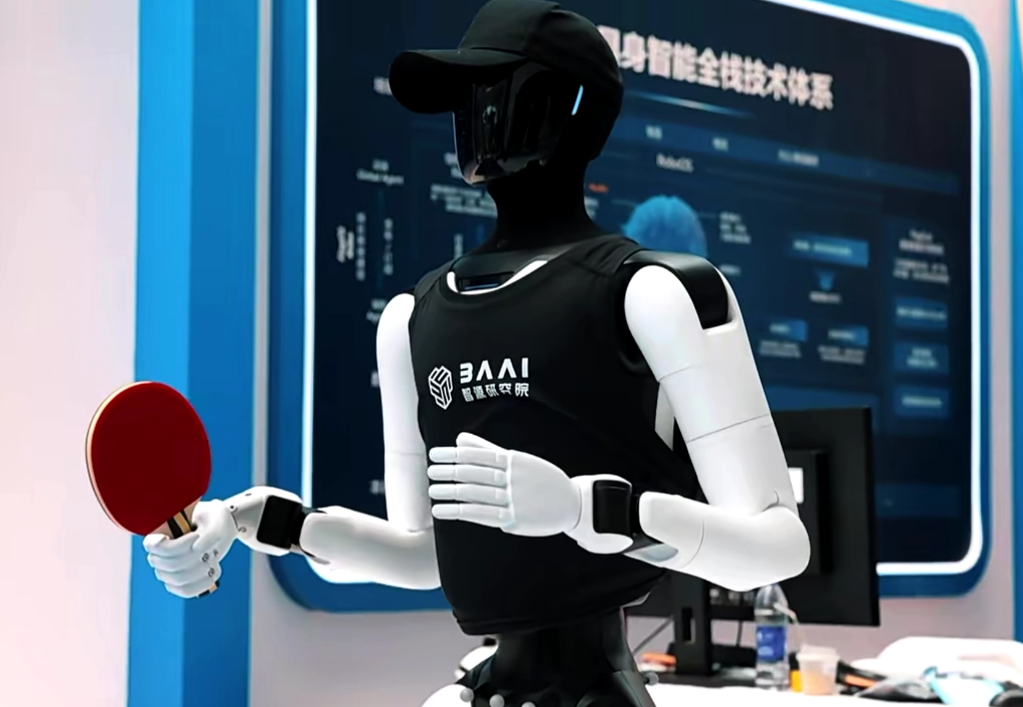
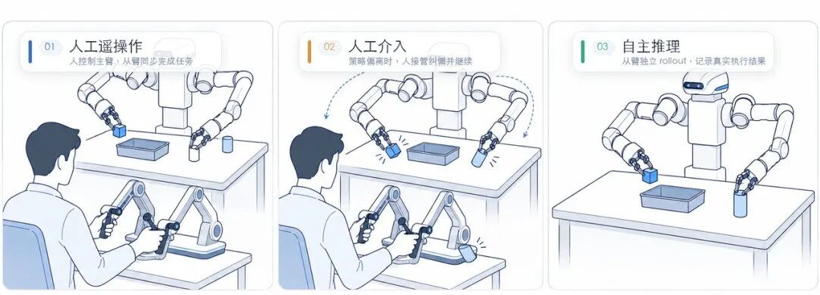
Gasgoo Munich- Gasgoo Embodied Intelligence reports that on September 17, Boden AI officially open-sourced the RW-RL-HIL-Dataset, a real-world robot reinforcement dataset. A subset of the RW-RL-Dataset, this collection focuses on human intervention data during actual robot deployments. It totals 82.23 hours across 3,347 episodes and 4.44 million frames, amounting to 188.57GB of data.Image Source: Boden AICovering nine household tasks, the dataset records real-world interaction processes including policy deployment, human takeover, correction, and handover. Data indicates that 3,068 episodes feature at least one human intervention, totaling 506,800 frames under human control—11.41% of all frames. The collection includes 6,408 continuous intervention segments, averaging 1.91 per episode with a mean duration of 5.27 seconds.Structured using the LeRobot v2.1 format, the dataset includes three video streams—head, left wrist, and right wrist—with 14-dimensional state and action vectors. Video is recorded at 640×360 resolution and 15FPS using H264 encoding, complete with frame-by-frame control flags and intervention boundary annotations. When combined with the main repository, this data supports research into human-in-the-loop imitation learning and reinforcement learning.Back in June, Boden AI teamed up with the JIP Innovation Center and Shanghai Jiao Tong University's MINT Lab to release the initial RW-RL-Dataset, topping 1,000 hours. To date, the company has open-sourced a total of 542 hours—comprising 460 hours of teleoperation data and 82 hours of real-world reinforcement data.On the operational front, Boden AI has established embodied robotics innovation centers across Ningbo, Huzhou, and Ma'anshan, spanning over 30,000 square meters. These facilities boast an annual capacity of 500,000 hours of real-world robot data and scenario data on the scale of millions of hours, underpinning R&D in embodied intelligence.

 +76 others