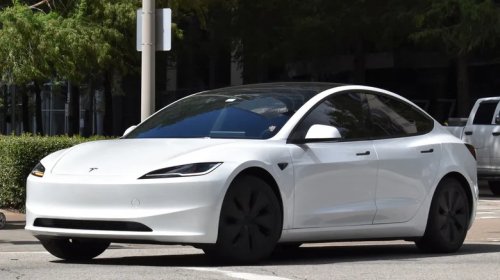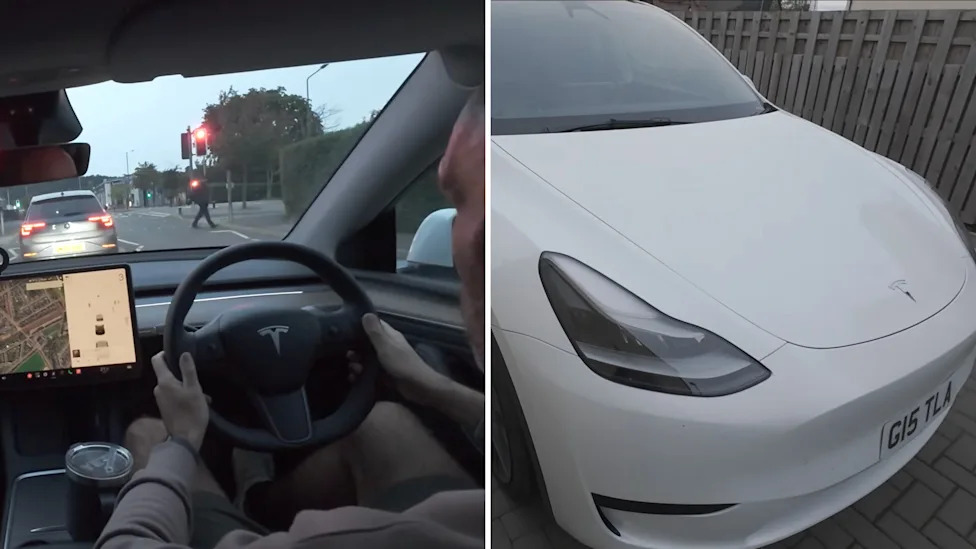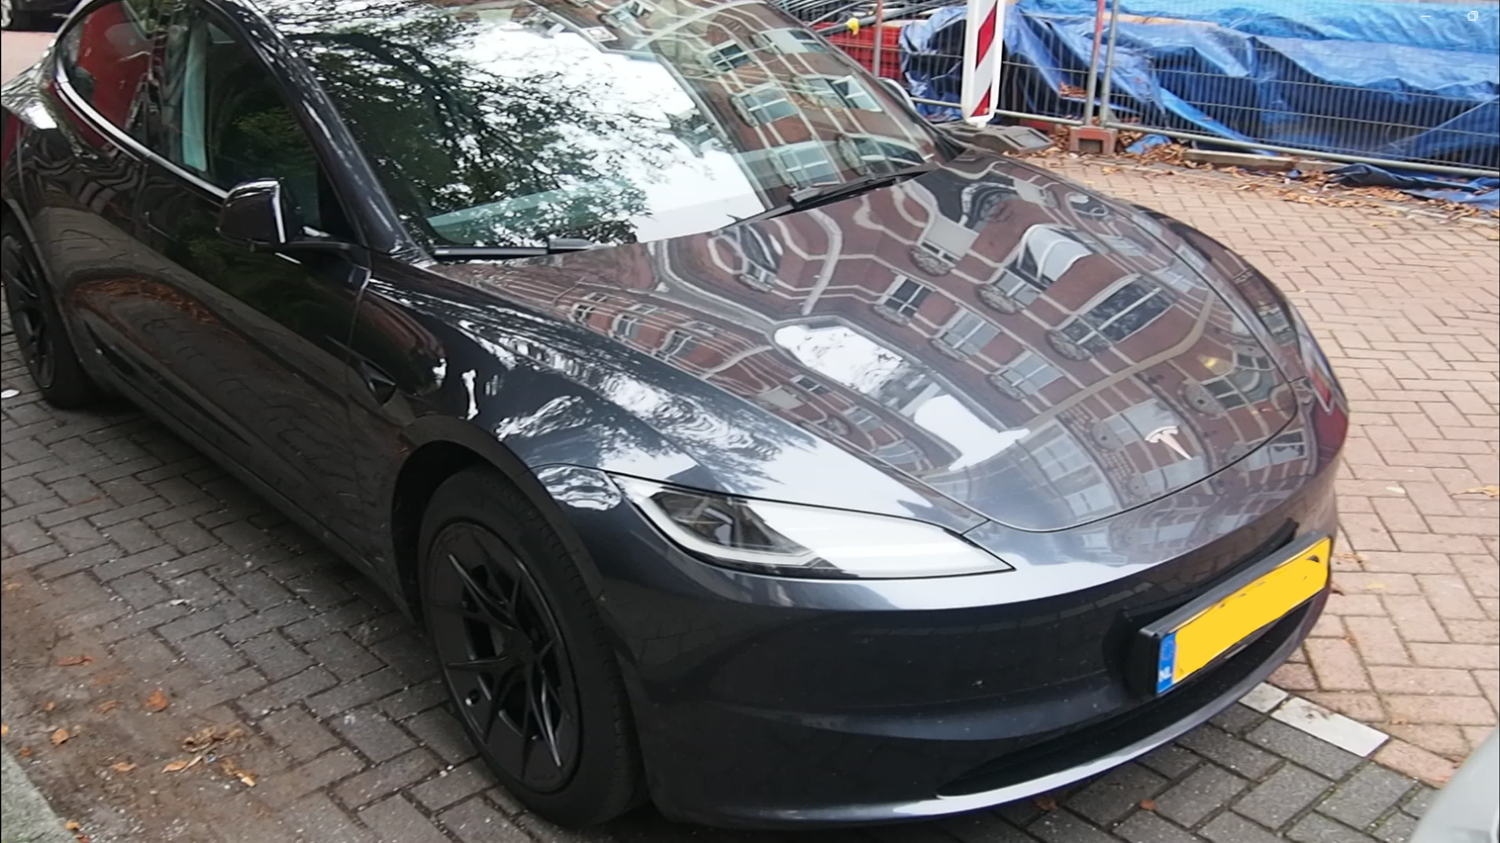
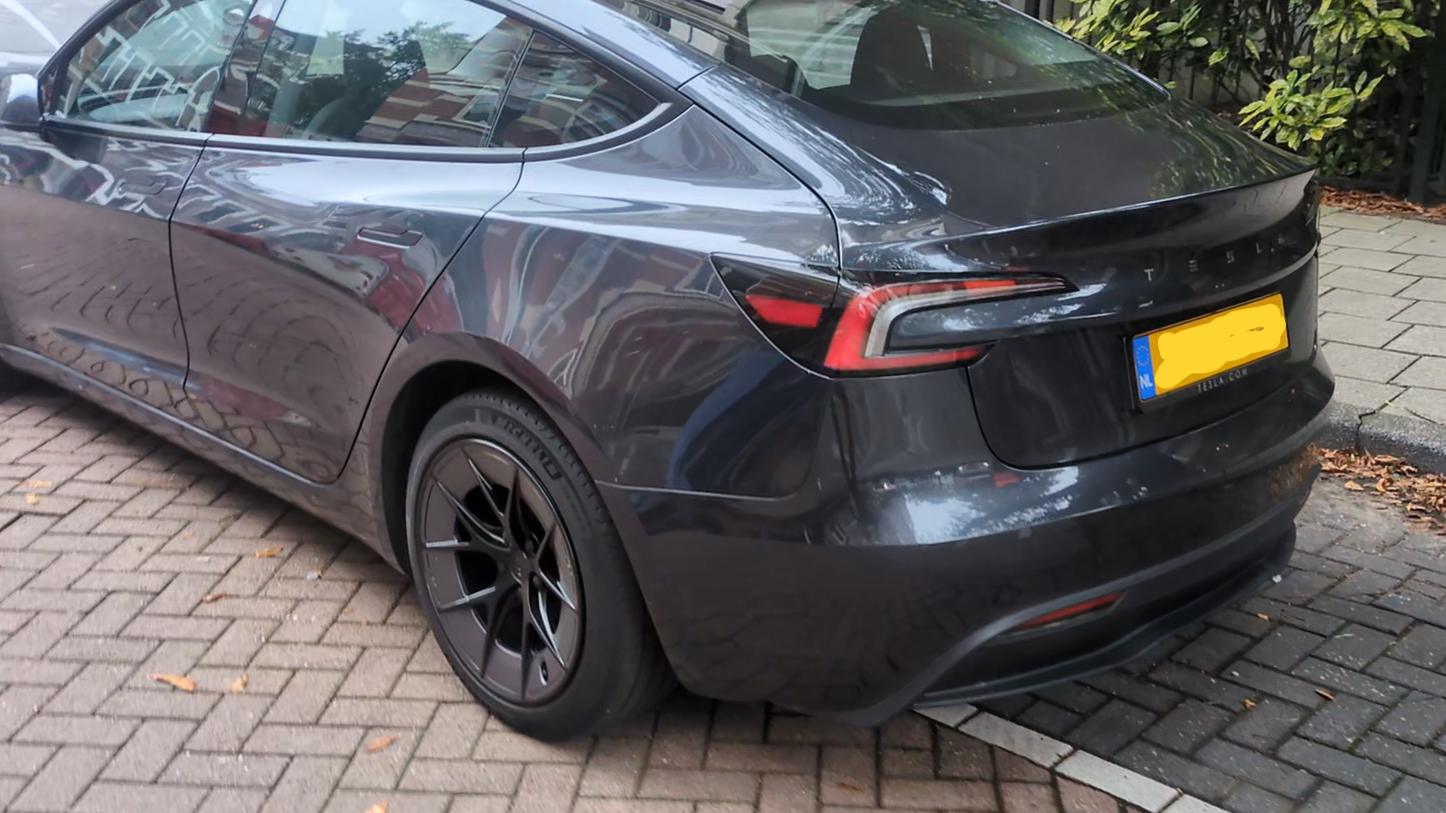
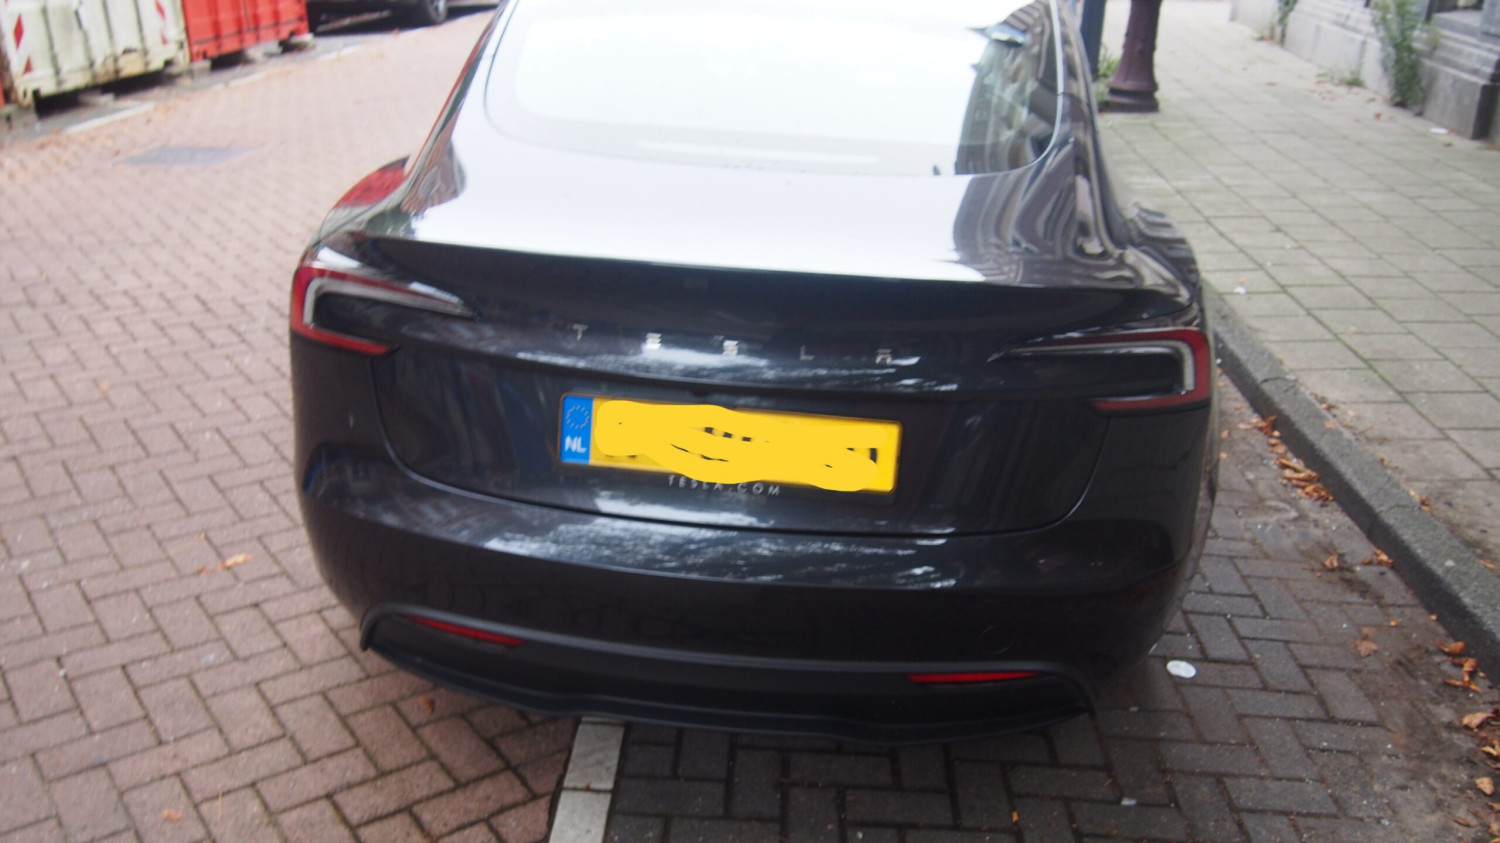
In the first part of this series, we rode in an XPENG L03 with VLA 2.0 in Amsterdam. For context, it is best to read that article first. In the second part, we switch to a Tesla Model 3 with FSD. While FSD is common in the US, it has not yet been approved in China, where XPENG’s VLA 2.0 is currently on the road. FSD is also not approved in most of Europe yet, but it was first given approval in the Netherlands and has been expanding into several other countries. As XPENG was testing VLA 2.0 in Amsterdam, this was the first opportunity to experience both systems on the same roads back-to-back. The car we rode in was a black Model 3 Highland. This particular example lacked a turn signal stalk. For Europe, the Model 3 is produced in Shanghai. The car was updated with the latest version of FSD, running on HW4. It was not a show-prepped vehicle, but rather a customer car that the owner lent to XPENG. Tesla cars are very popular in the Netherlands, so we easily blended in. Due to some camera difficulties, I ended up taking the test loop in the Tesla twice. This worked out for the best. The same driver from the L03 video was able to join me on the second Tesla lap as well, sharing his perspective and providing consistency in driver risk tolerance. As with the XPENG test, we faced challenges that go far beyond what most would ever experience in the US, from the proliferation of bicycles to the complicated traffic patterns. However, as the Tesla lap was a bit later in the day, traffic had noticeably subsided. FSD: React & Correct With Tesla FSD, the overall theme was reacting and then correcting. If it saw a bicycle coming at a distance, it would react, brake abruptly, and then go forward when it determined that it had time to make it through a maneuver. It would tend to leave a somewhat larger gap in the process. In some ways, this overly cautious approach could be seen as safer. However, those reactions could cause other issues. In one case, it abruptly stopped in the middle of the bike lane for an oncoming cyclist at a distance and stayed there long enough that it ended up blocking a bike coming from the other direction on the other side of the bike lane. In another case, it stopped at a green light while a pedestrian approached an intersection but did not enter it. By the time FSD figured out what was happening, the light had gone from green to red. In another case, it stopped abruptly for someone approaching an intersection while the light was changing, and then left after the light had turned red. In one instance, it was overly cautious on yellow and stopped when it could have made it through the intersection. Of the two cars on the test loop, only the Tesla had people honk at it. This was largely due to how it responded at intersections. Sometimes it was overly cautious and held up traffic. Once, it stopped in the middle of the road and blocked the tram line and multiple lanes of traffic. On one waypoint during the first lap, it stopped in the middle of an intersection at a side street and would not reengage. The Tesla also had issues picking the right lane. On several occasions, it made turns from the wrong lane. In one case, it got into the right turn lane when we were turning left and was going to loop the block. The driver took over to get back into the correct lane. Reacting and correcting also applied to steering. In one case on the first lap, it didn’t see a median early enough and had to shift abruptly when making a turn. However, even in low-speed maneuvers, the steering wheel tends to move in spurts: turn, correct, turn, correct… It is not as noticeable when FSD is operating in isolation, but it appears as a significant difference after riding with VLA 2.0. When making some of those rapid corrections, you could sense the tires slipping slightly on the slick, wet bricks. I would like to test these systems again in snow or ice to see how they perform in even slipperier conditions. Tesla Model 3 in Amsterdam. Photo by Larry Evans “React and correct” has another double-edged nature to it. Abrupt braking for a bicycle in the distance might err on the side of caution for that bicycle, even if it is beyond what is necessary. However, the car behind you may not anticipate the sudden braking. As such, they may not stop in time and could rear end you. This potential impact is likely to be considered the other car’s fault, but an impact is still an impact. When accelerating, the Tesla was not as smooth. In many cases, it would hesitate before taking off. Then, it would lurch off the line initially and then slow, then accelerate more. It was overall less comfortable. While I didn’t have a stopwatch, it likely didn’t accelerate faster overall to the desired speed. It just started later, took off faster and then slowed, rather than a consistent rate of acceleration. In addition, it would accelerate to beyond the speed limit based on user settings, although that function may be going away in Europe with new UN DCAS regulations, which also require hands on the wheel during urban driving. As traffic depleted while the day progressed, the circumstances were a bit different by my third loop. In areas with less traffic, the Tesla felt more comfortable. With less stopping and accelerating, the Tesla also felt smoother. Amsterdam is an extreme driving scenario. When operating on more open roads with fewer obstacles, like most of the US, FSD would be a good option. The latest version feels better than the version that I had driven a few months ago in the US. FSD did have difficulty exiting and entering street parking spaces autonomously. In each case, the driver needed to take over. Part of this has to do with the tight parking spaces in Amsterdam. However, while attempting self-parking, FSD indicated it had parked successfully, but was still part way into traffic. The driver needed to re-park closer to the curb. This also might not be as much of a concern in the US, where the spaces are not as narrow. The Tesla was able to drive around obstacles with a gap of an inch or two. However, it was not a quick or smooth process, making multiple corrections while moving slowly. If given enough time, it was able to accomplish the maneuver. That said, it would be a challenge if the car made it halfway through and then gave up, as it could be difficult for the human to get out of the situation. Due to the design of the vehicle, it is a bit harder to know where the corners are, especially when the driver is less familiar with the car. Luckily, we didn’t get stuck in any tight spots. Tesla Model 3 in Amsterdam. Photo by Larry Evans Waypoints were a challenge for the Tesla. Sometimes it would miss the waypoint and then try to turn around. In one case, it missed the waypoint, drove around, missed it again and then tried to go down another road to make another loop. In that instance, the driver took over and then reengaged FSD when the waypoint was deleted and the car was moving in the right direction again. In another, it tried to stop for a waypoint in the middle of a road, blocking traffic. Then, when the waypoint was deleted, FSD sometimes wouldn’t reengage or took a few seconds to take off again. In general, many drivers will not use waypoints while driving. However, as vehicles approach higher levels of autonomy, the ability to navigate to specific points becomes more important. When maneuvering through construction-related roadblocks, the Tesla would sometimes make the wrong move, resulting in a takeover to get back on the right track. We also went down the wrong lane for a significant length after going up over a curb to get around a stopped vehicle. The Tesla waited for another break in the curb to return to the correct side of the road. We passed a cop coming toward us in our lane, but he luckily didn’t turn around to give us a ticket. However, there was also an instance where the Tesla backed up to accommodate oncoming construction equipment. That was impressive. Backing up will be necessary for some narrow, one lane roads in Europe, as seen in parts of Greece. Reverse operation was not yet activated on the L03 prototype, but that gives XPENG something to work on. Overall, the Tesla felt like a driver from middle America trying to drive in Amsterdam. The traffic patterns are more complex than those in NYC, and far more complex than in a city like Austin. It felt overly cautious and nervous, not being fully adapted to the complex traffic and road conditions. In different circumstances with a different frame of reference, it would likely feel more comfortable. In the third part of this series, I will get into more details of the cars and compare some of the differences. But you can also compare it to the previous XPENG L03 video: